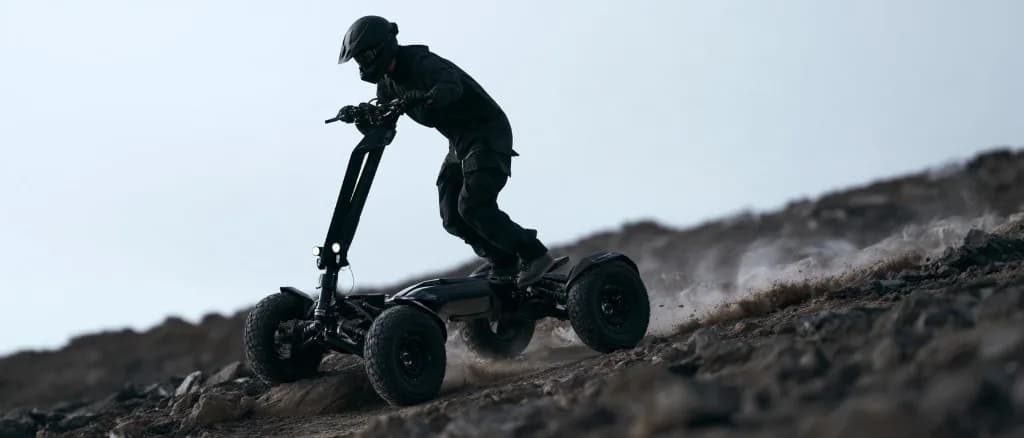
All terrain electric scooter
Firmware development for an all terrain electric scooter, with embedded control software developed to manage the vehicle electronics and motor system.
The brief
The project required embedded firmware for an all terrain electric scooter. Denotec developed the software responsible for controlling and coordinating the scooter's electronic systems, with a focus on reliable operation and responsive vehicle control.
The constraint
The firmware needed to operate reliably across a demanding range of riding conditions while responding predictably to changes in rider input and the vehicle's operating state. The software also had to integrate cleanly with the existing electronic hardware.
Our approach
Denotec developed the embedded firmware around the scooter's existing electronics and control requirements. The software was structured to manage the vehicle's operating states and motor control while providing consistent behaviour across different operating conditions.
The outcome
The completed firmware was integrated with the scooter electronics and validated as part of the finished vehicle. The resulting control software provided the embedded functionality required for reliable operation of the all terrain electric scooter.
Firmware source